Published:
by
Yunwoo Lee
GAR-Tracker Accepted to IEEE Access
Accepted to IEEE Access.
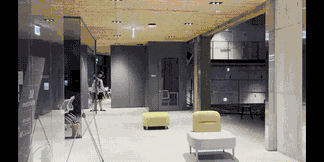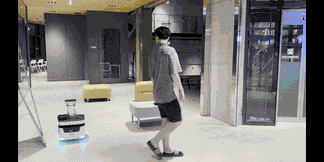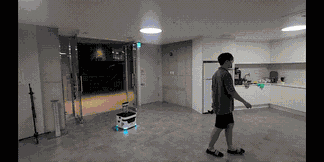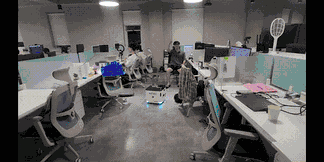
We are excited to announce that our paper, “GAR-Tracker: Target-Visible Trajectory Planning for a Ground Assistant Robot,” has been accepted to IEEE Access.
Read more about the project on the research page.